
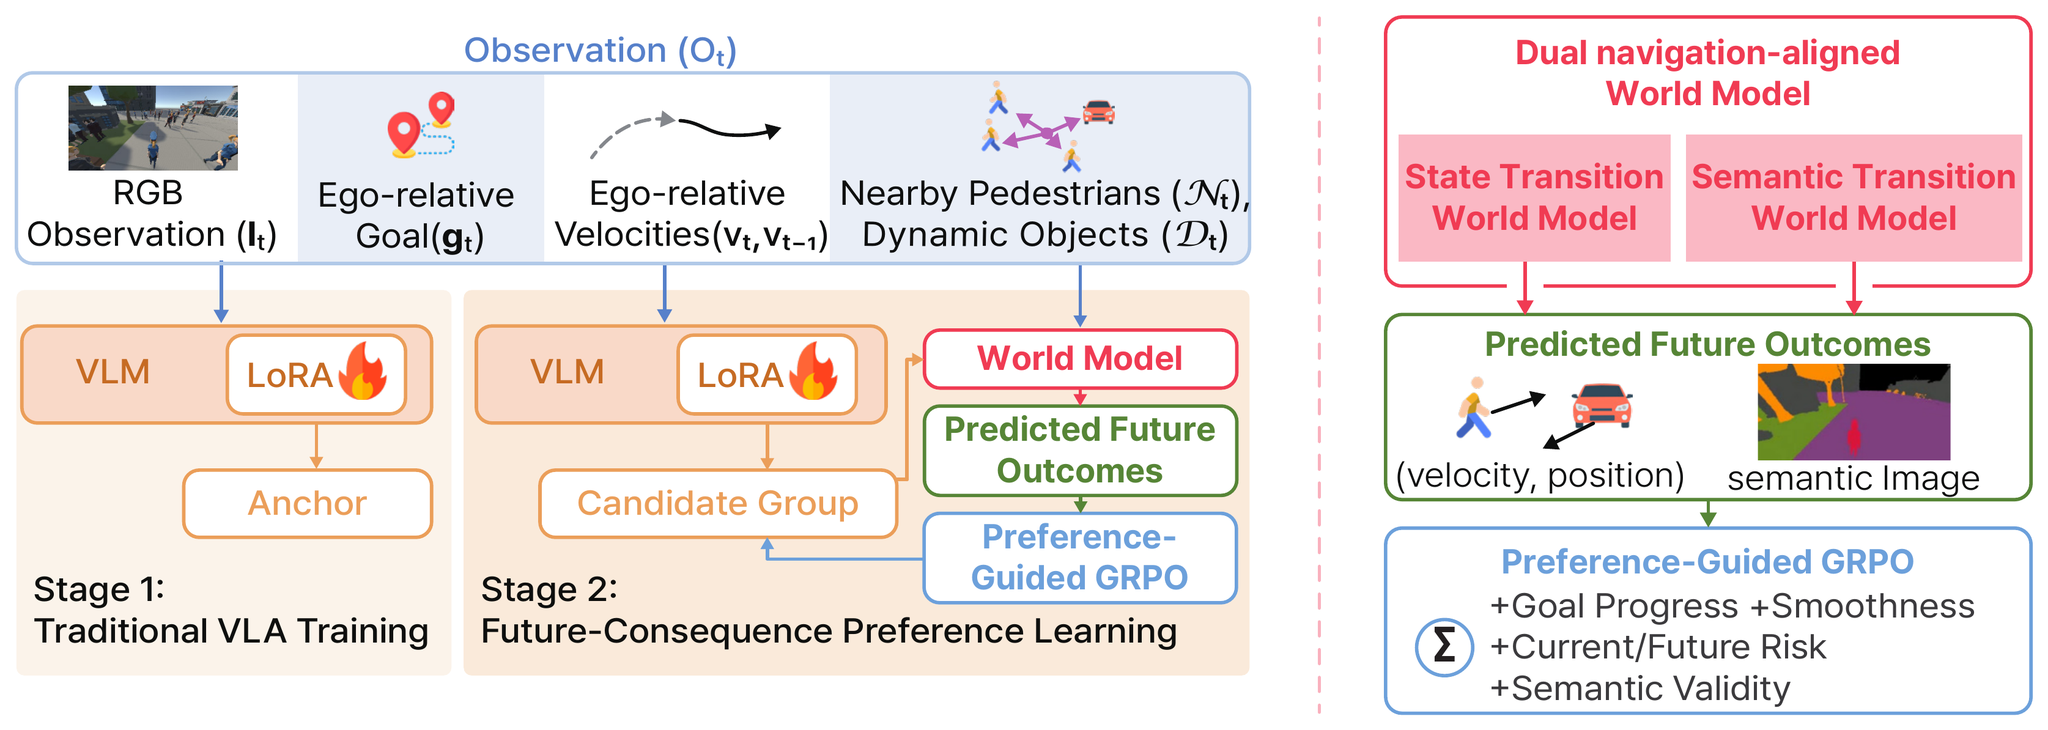
Seeing Beyond the Next Step: World-Model-Guided Human-Like Navigation in Multi-Agent Scenes
NeurIPS 2026 Conference Paper
A framework that distills the foresight of dual task-aligned world models into a fast navigation policy at training time, enabling safer and more human-like navigation in multi-agent scenes without inference-time rollouts.


